金甲虫
电脑杂谈 发布时间:2020-04-16 17:06:16 来源:网络整理
边缘像素是图像中的灰度突然改变的像素,边缘是连接的边缘像素的集合. 边缘检测是一种用于检测边缘像素的局部图像处理方法.
使用<;
中引入的拉普拉斯算子
输出图像是
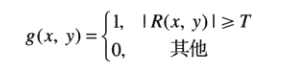
卷积模板
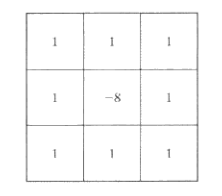
该代码之前已经实现,因此不会在本文中进行测试
图像渐变
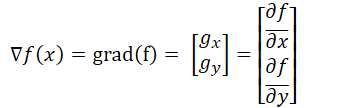
渐变矢量大小

在图像处理过程中,平方和和平方根的计算速度较慢,因此简化为以下计算方法
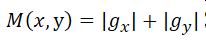
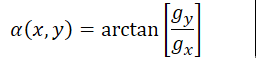
梯度矢量的方向与x轴之间的角度
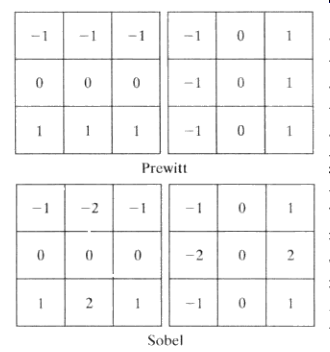
根据不同的偏导数计算方法,获得了不同的边缘检测模板
原始图片
使用Sobel模板检测水平边缘

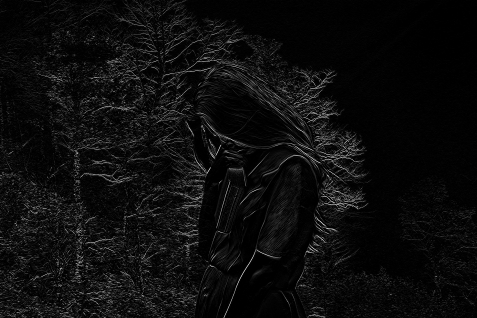
使用Sobel模板检测垂直边缘
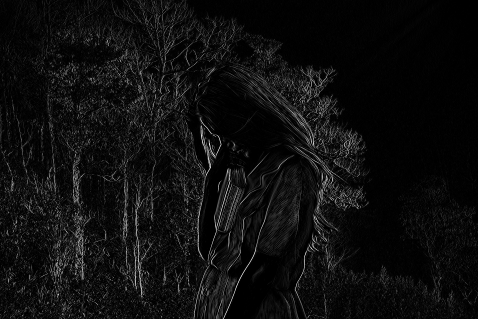
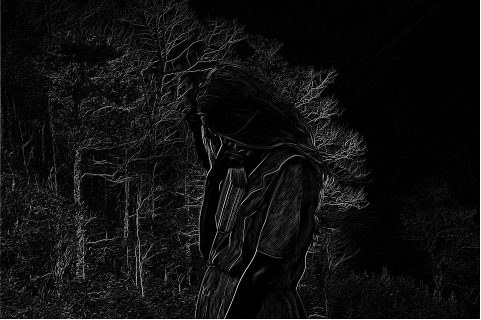
添加两个
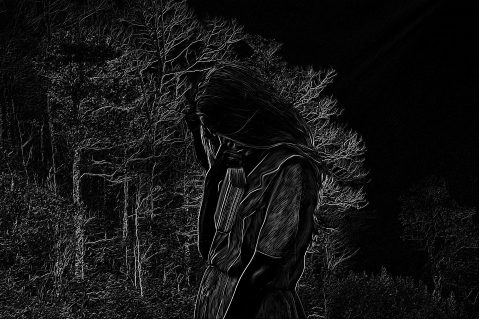
代码实现
 1 void edge_detection(short** in_array, short** out_array, long height, long width)
 2 {
 3     short gx = 0, gy = 0;
 4     short** a_soble1;
 5     short** a_soble2;
 6
 7     a_soble1 = allocate_image_array(3, 3);
 8     a_soble2 = allocate_image_array(3, 3);
 9     for (int i = 0; i < 3; i++){
10         for (int j = 0; j < 3; j++){
11             a_soble1[i][j] = soble1[i][j];
12             a_soble2[i][j] = soble2[i][j];
13         }
14     }
15     for (int i = 0; i < height; i++){
16         for (int j = 0; j < width; j++){
17             gx = convolution(in_array, i, j, height, width, a_soble1, 3);
18             gy = convolution(in_array, i, j, height, width, a_soble2, 3);
19             // out_array[i][j] = gx;
20             // out_array[i][j] = gy;
21             out_array[i][j] = gx + gy;
22             if (out_array[i][j] < 0)
23                 out_array[i][j] = 0;
24             else if (out_array[i][j] > 0xff)
25                 out_array[i][j] = 0xff;
26         }
27     }
28     free_image_array(a_soble1, 3);
29     free_image_array(a_soble2, 3);
30 }
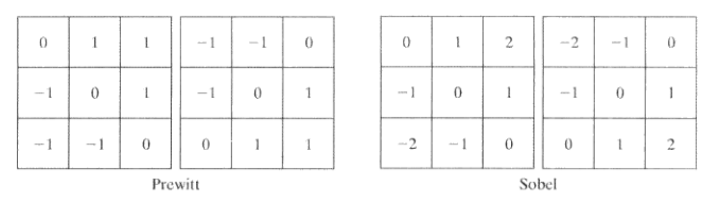
Sobel 45°检测模板

Sobel -45°检测模板
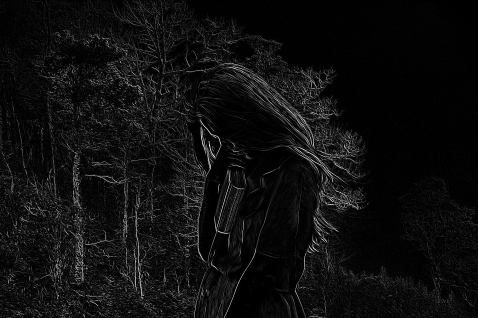
添加两个
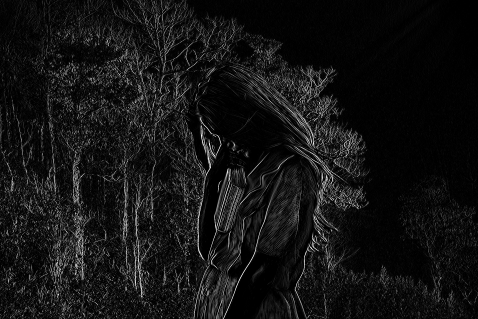
代码已实现,只需替换模板值
1. 采样二维高斯函数以获得高斯低通滤波器,对输入图像进行滤波,滤波器模板的大小是大于或等于6 *σ的最小奇数整数
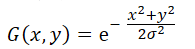
算法实现
 1 void generate_gaussian_filter(double** gaussian_filter, long sigma)
 2 {
 3     double x, y;
 4     long filter_size = 6 * sigma + 1;
 5
 6     for (int i = 0; i < filter_size; i++){
 7         for (int j = 0; j < filter_size; j++){
 8             x = i - filter_size / 2;
 9             y = j - filter_size / 2;
10             gaussian_filter[i][j] = exp(-1.0 * ((pow(x, 2) + pow(y, 2)) / 2 * sigma * sigma));
11         }
12     }
13 }
2. 使用以下模板,计算第一步中获得的图像的拉普拉斯算子


算法实现
 1 void laplace(short** in_array, short** out_array, long height, long width)
 2 {
 3     short** a_sharpen;
 4
 5     a_sharpen = allocate_image_array(3, 3);
 6     for (int i = 0; i < 3; i++){
 7         for (int j = 0; j < 3; j++){
 8             a_sharpen[i][j] = sharpen[i][j];
 9         }
10     }
11     for (int i = 0; i < height; i++){
12         for (int j = 0; j < width; j++){
13             out_array[i][j] = convolution(in_array, i, j, height, width, a_sharpen, 3);
14         }
15     }
16     free_image_array(a_sharpen, 3);
17 }
运行结果
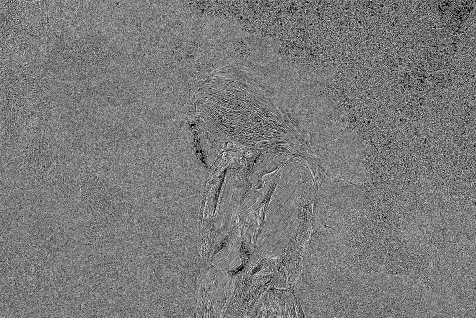
3. 寻找零交叉,对于任何像素p,测试上下两个,对角线c图像识别,两个对角线的四个位置,当存在两对符号不同且绝对值差大于某个阈值的点时为零.
算法实现
 1 int is_cross(short** in_array, long row, long column)
 2 {
 3     int cross_num = 0;
 4
 5     if (in_array[row-1][column-1] * in_array[row+1][column+1] < 0 &&
 6         abs(abs(in_array[row-1][column-1]) - abs(in_array[row+1][column+1])) > 0x66)
 7         cross_num++;
 8     if (in_array[row-1][column] * in_array[row+1][column] < 0&&
 9         abs(abs(in_array[row-1][column]) - abs(in_array[row+1][column])) > 0x66)
10         cross_num++;
11     if (in_array[row-1][column+1] * in_array[row+1][column-1] < 0&&
12         abs(abs(in_array[row-1][column+1]) - abs(in_array[row+1][column-1])) > 0x66)
13         cross_num++;
14     if (in_array[row][column-1] * in_array[row][column+1] < 0&&
15         abs(abs(in_array[row][column-1]) - abs(in_array[row][column+1])) > 0x66)
16         cross_num++;
17
18     if (cross_num >= 2)
19         return 1;
20     else
21         return 0;
22 }
 1 void marr(short** in_array, short** out_array, long height, long width)
 2 {
 3     long sigma = 2;
 4     long filter_size = 6 * sigma + 1;
 5     double** gaussian_filter;
 6     short **gauss_array, **laplace_array;
 7
 8     gaussian_filter = allocate_double_array(filter_size, filter_size);
 9     gauss_array = allocate_image_array(height, width);
10     laplace_array = allocate_image_array(height, width);
11     generate_gaussian_filter(gaussian_filter, sigma);
12
13     for (int i = 0; i < height; i++){
14         for (int j = 0; j < width; j++){
15             gauss_array[i][j] = convolutiond(in_array, i, j, height, width, gaussian_filter, filter_size);
16         }
17     }
18     printf("Gasuuian filter done\n");
19     laplace(gauss_array, laplace_array, height, width);
20     printf("Laplace done\n");
21     zero_cross(laplace_array, out_array, height, width);
22     printf("Zero cross done\n");
23
24     free_double_array(gaussian_filter, filter_size);
25     free_image_array(gauss_array, height);
26     free_image_array(laplace_array, height);
27 }
最终运行结果
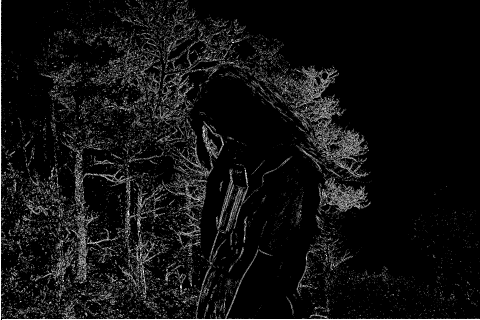
可以看出,该算法检测到的边缘与物体的真实边缘更加吻合,但是这些边缘由离散点组成c图像识别,因此需要进行边缘连接以进行进一步处理,本文将不再赘述. 在这里,有兴趣的读者可以进行更深入的研究.
本文来自电脑杂谈,转载请注明本文网址:
https://www.pc-fly.com/a/jisuanjixue/article-177804-1.html
相关阅读
发表评论 请自觉遵守互联网相关的政策法规,严禁发布、暴力、反动的言论
-

-
高振迪
特工在我国从事反华活动吗
 如何使用U盘安装系统,教您如何使用U盘引导进入PE安装系统
 如何解决Win10中不安装字体的问题?
 图1是常染色体遗传疾病的谱系.
 电脑报警声的含义有哪些?电脑的硬件问题出自哪里?
美国欺负到门上了